Work
Building new control theory and autonomy tools at Dr. Poveda's INCEPTION lab, funded by the Office of Naval Research (ONR) and the Air Force Research Laboratory (AFRL), for robots that have to work when it counts.
Putting that theory on robots like rovers, drones, submarines and surface vessels at Dr. Nili's Dynamic Systems and Intelligent Machines lab, funded by the Office of Naval Research (ONR) and the Air Force Research Laboratory (AFRL), where it finds out whether it was right.
Owned autonomy for GRIFFIN, a robot that drives and flies through industrial spaces people should not enter. Took it from bench to production and put it in front of customers.
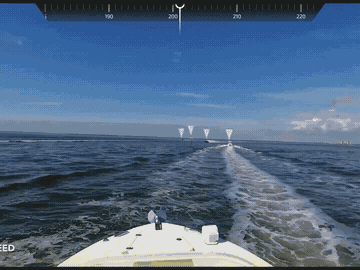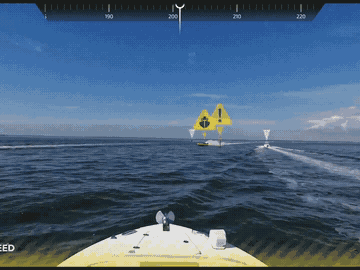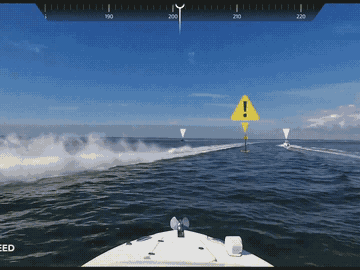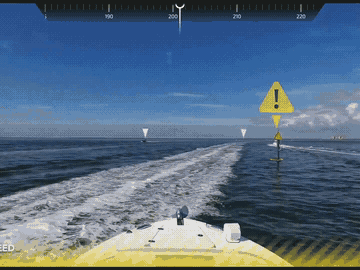
Perception and planning for a fleet of 70 autonomous surface vessels running with the US Coast Guard, the US Navy and commercial operators.
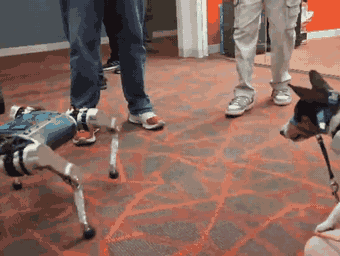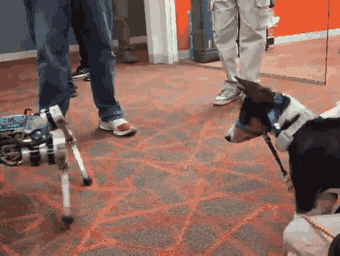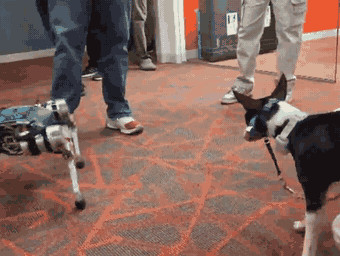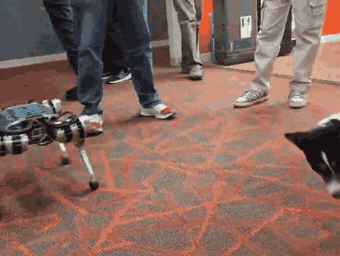
Built the locomotion controller for the Terrier quadruped from prototype, taking it from a policy trained across 4000 simulated robots to one that walks on hardware.
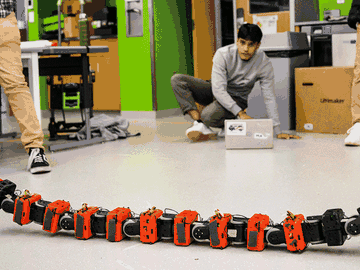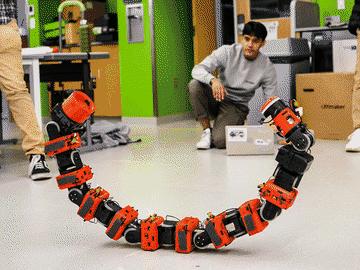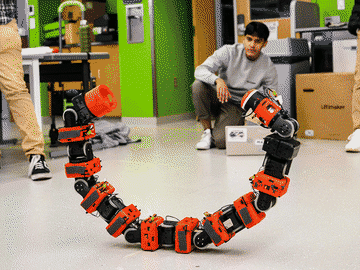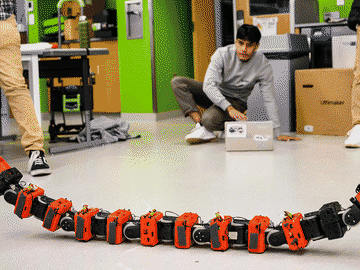
Perception, controls and autonomy for three robots: COBRA, the NASA-funded snake robot that took the Artemis Award, Harpy, a thruster-assisted biped built with Caltech, and Husky, a quadruped that flies.
Master's in Robotics, focused on control systems engineering and autonomy. Two years of building and testing robots that had to work outside the lab.
Perception and planning for an autonomous EV aimed at Indian traffic. The prototype I built raised the company's first round.
Four years of mechanisms, dynamics, thermodynamics and control systems. My first principles understanding of the world around us started here.